
Delto Gripper ROS 2 Packages for Tesollo's Robotic Grippers
Product Lineup
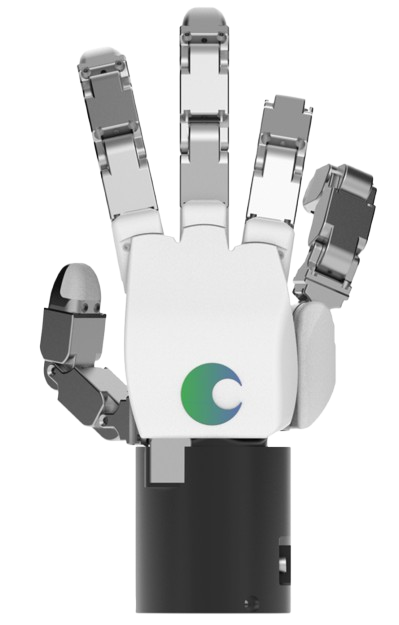
DG-5F
5-Finger Hand
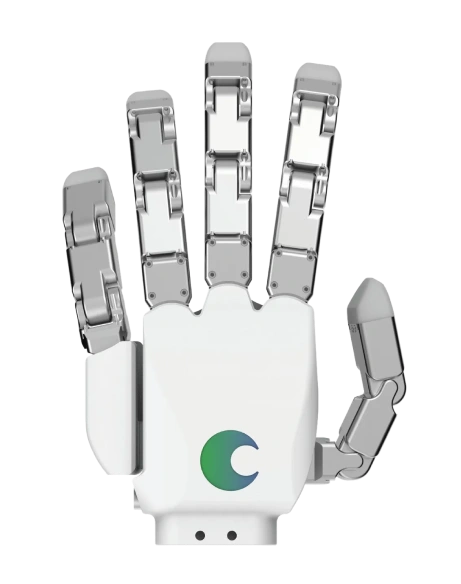
DG-5F-S
5-Finger Small
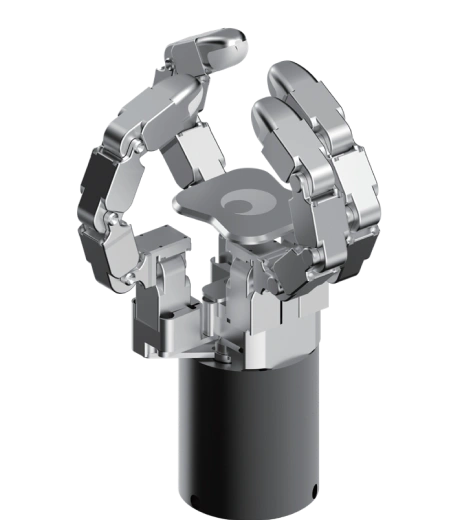
DG-4F
4-Finger Gripper
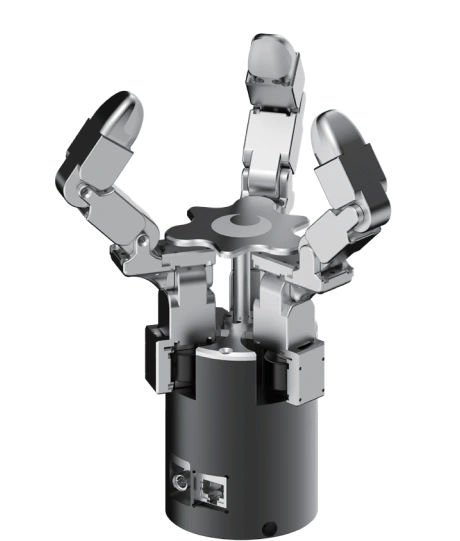
DG-3F-M
3-Finger Gripper
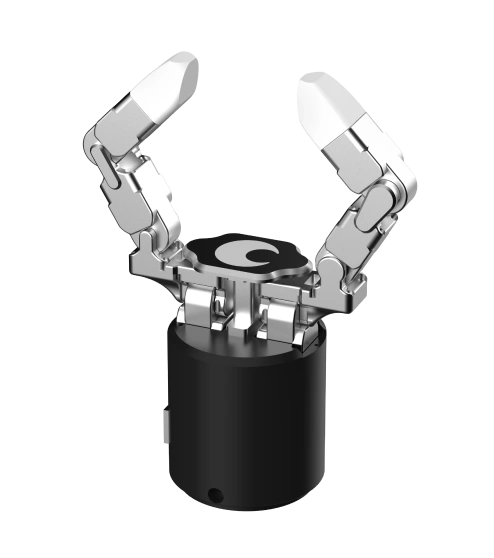
DG-2F
2-Finger Gripper
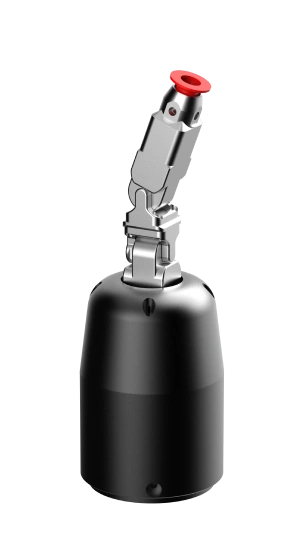
DG-1F
1-Finger Gripper
Quick Start
# Clone into the src/ directory of a ROS 2 workspace (example: DG-5F left hand)
mkdir -p ~/ros2_ws/src && cd ~/ros2_ws/src
git clone https://github.com/tesollodelto/tesollo_ros2.git
cd tesollo_ros2
git submodule update --init dg5f_ros2 dg_common/dg_tcp_comm dg_common/dg_hardware
# Optional: include dg_sdk_ros2_bridge if you need the Delto SDK bridge
# git submodule update --init dg_sdk_ros2_bridge

# Build
cd ~/ros2_ws && colcon build --symlink-install && source install/setup.bash

# Launch
ros2 launch dg5f_driver dg5f_left_driver.launch.py
📦
Installation
Setup guide
🚀
Quick Start
Get running fast
🏗️
Architecture
How it works
📖
API Reference
Messages & Services